Vector-level kernels of the steepest-descent optimizer. More...
Functions/Subroutines | |
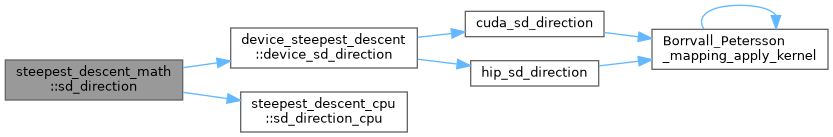
| subroutine, public | sd_direction (s, x, xmin, xmax, n) |
| Bound-projected steepest-descent direction (Eq. D22). | |
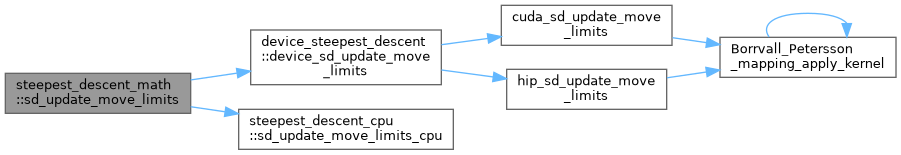
| subroutine, public | sd_update_move_limits (delta, x, x1, x2, dec, inc, dmin, dmax, n) |
| Adapt the move limits (Eq. D23). | |
| subroutine, public | sd_update_design (x_new, x, s, delta, psi, smax, xmin, xmax, n) |
| Move-limited, box-constrained design update (Eq. D24). | |
Detailed Description
Elementwise kernels of the steepest descent method with move limits, Appendix D of da Silva, Aage, Beck & Sigmund (2021), Eqs. D22-D24. Each routine operates on vector_t objects and runs on the device backend when one is configured, and on the CPU otherwise. All three are local operations; the global reduction of the direction is left to the caller.
Function/Subroutine Documentation
◆ sd_direction()
| subroutine, public steepest_descent_math::sd_direction | ( | type(vector_t), intent(inout) | s, |
| type(vector_t), intent(in) | x, | ||
| real(kind=rp), intent(in) | xmin, | ||
| real(kind=rp), intent(in) | xmax, | ||
| integer, intent(in), optional | n | ||
| ) |
On entry s holds the gradient G. On exit it holds S = -G, with S_e = 0 where x_e >= xmax and S_e > 0, or x_e <= xmin and S_e < 0.
- Parameters
-
[in,out] s Gradient on entry, projected direction on exit. [in] x Design variables. [in] xmin Lower bound of the design variables. [in] xmax Upper bound of the design variables. [in] n Number of entries to process, the size of sby default.
Definition at line 65 of file steepest_descent_math.f90.
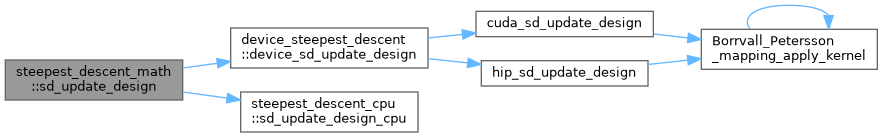
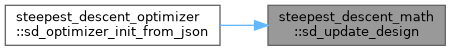
◆ sd_update_design()
| subroutine, public steepest_descent_math::sd_update_design | ( | type(vector_t), intent(inout) | x_new, |
| type(vector_t), intent(in) | x, | ||
| type(vector_t), intent(in) | s, | ||
| type(vector_t), intent(in) | delta, | ||
| real(kind=rp), intent(in) | psi, | ||
| real(kind=rp), intent(in) | smax, | ||
| real(kind=rp), intent(in) | xmin, | ||
| real(kind=rp), intent(in) | xmax, | ||
| integer, intent(in), optional | n | ||
| ) |
Computes x_new = min(xmax, max(xmin, min(x + delta, max(x - delta, x + psi * (s / smax))))). This equals Eq. D24 whenever x lies in [xmin, xmax], and stays well defined for infeasible x.
- Parameters
-
[in,out] x_new Updated design variables. [in] x Current design variables. [in] s Bound-projected steepest-descent direction. [in] delta Move limits. [in] psi Step length. [in] smax Global maximum of the absolute value of s, which must be positive.[in] xmin Lower bound of the design variables. [in] xmax Upper bound of the design variables. [in] n Number of entries to process, the size of x_newby default.
Definition at line 145 of file steepest_descent_math.f90.
◆ sd_update_move_limits()
| subroutine, public steepest_descent_math::sd_update_move_limits | ( | type(vector_t), intent(inout) | delta, |
| type(vector_t), intent(in) | x, | ||
| type(vector_t), intent(in) | x1, | ||
| type(vector_t), intent(in) | x2, | ||
| real(kind=rp), intent(in) | dec, | ||
| real(kind=rp), intent(in) | inc, | ||
| real(kind=rp), intent(in) | dmin, | ||
| real(kind=rp), intent(in) | dmax, | ||
| integer, intent(in), optional | n | ||
| ) |
With d_e = (x_e - x1_e) * (x1_e - x2_e), the move limit is scaled by dec where d_e < 0, by inc where d_e > 0, left unchanged where d_e = 0, and then clamped to [dmin, dmax].
- Parameters
-
[in,out] delta Move limits. [in] x Design variables at the current iteration. [in] x1 Design variables one iteration back. [in] x2 Design variables two iterations back. [in] dec Factor applied on oscillation. [in] inc Factor applied on monotone progress. [in] dmin Smallest allowed move limit. [in] dmax Largest allowed move limit. [in] n Number of entries to process, the size of deltaby default.
Definition at line 103 of file steepest_descent_math.f90.